About Us
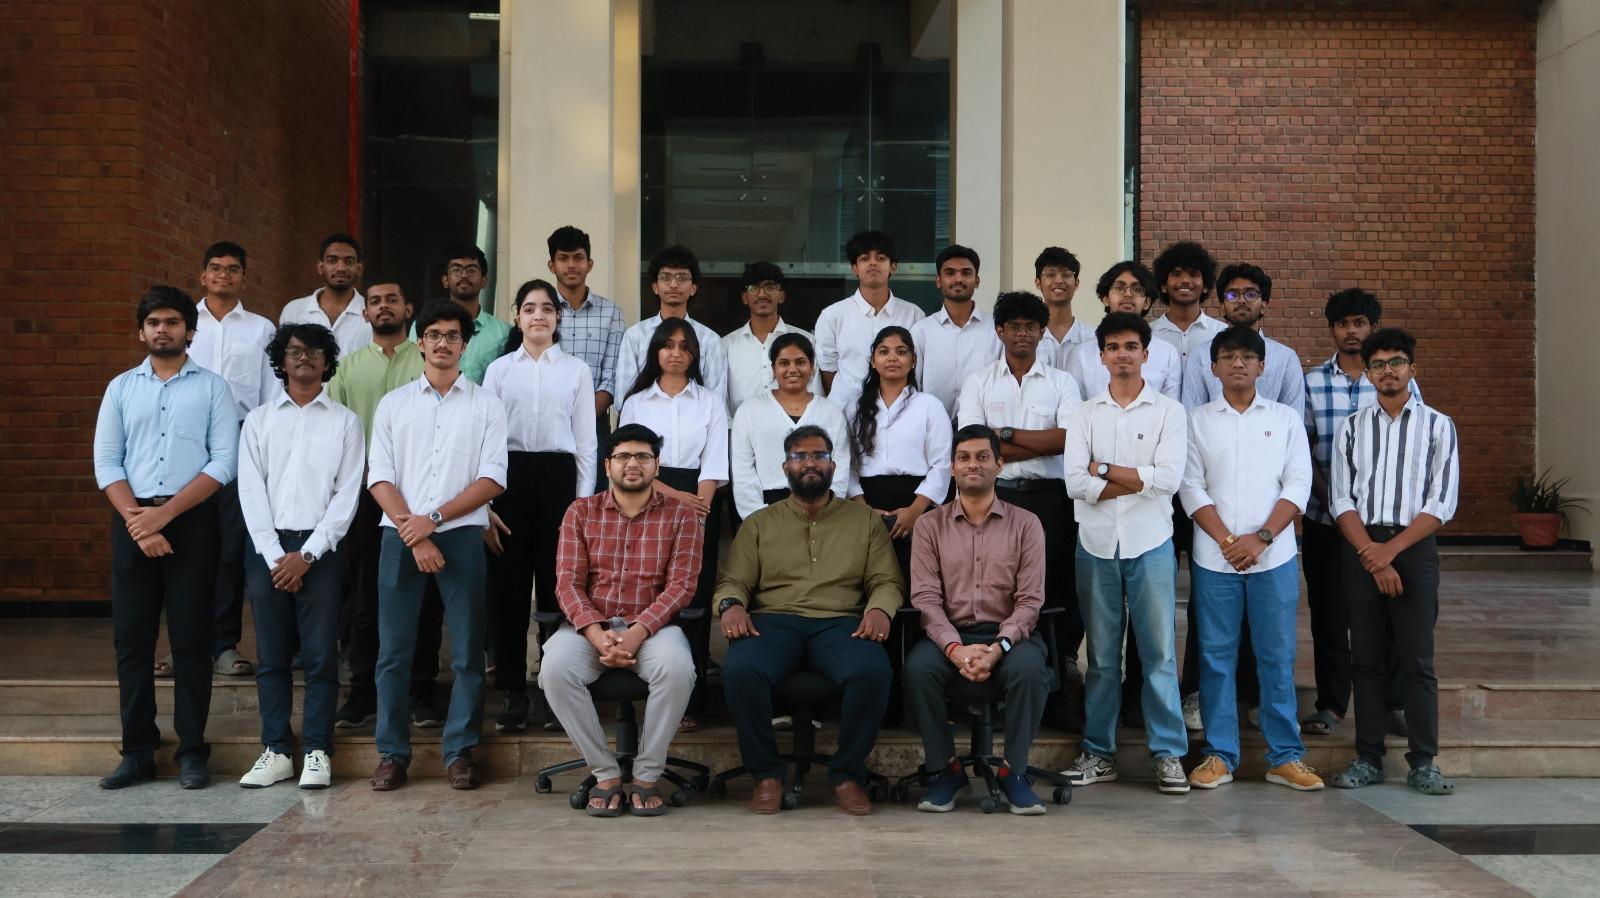
AUV SOCIETY IIITDM — We are a team of interdisciplinary undergraduate engineers dedicated to building autonomous underwater vehicles for premier international robotics competitions. Our team integrates mechanical engineering, advanced embedded electronics, and autonomous software. We aim to synthesize theoretical knowledge with real-world engineering to fabricate underwater vehicles that traverse the ocean depths and operate fully autonomously.
The club's objective is to foster innovation and pioneering research in underwater robotics. We develop autonomous systems capable of complex subsea tasks including acoustic localization, object detection, obstacle navigation, and robotic arm manipulation in variable underwater conditions.
AUV IIITDM provides hands-on exposure in computer vision, deep learning, control algorithms, and rapid prototyping, representing India with distinction in national and global arenas like SAUVC (Singapore).
Who We Are
Current Projects & Initiatives
Mechanical
- Bio-inspired gripping mechanism for deep-water object retrieval
- Multi-axis underwater robotic manipulator
- Hydrodynamic pressure hull and lightweight chassis design
Electronics
- Magnetic Kill Switch (Deployment on Moses & Nebula v2)
- Array Hydrophones for acoustic pinger localization
- ADRC controller replacing traditional PID for robust real-world stability
Software
- High-throughput custom Pub-Sub architecture replacing ROS overhead
- Lock-free ring buffer IPC for single-host low-latency sensor streaming
- ML-based autonomous PID tuning for real-time hydrodynamic adaptation